Research
MIT's FLEX lets robots infer intent from natural language
MIT News AIhigh confidence
Why it matters
- →Robots can now infer broader safety constraints from specific natural language warnings.
- →The system reduces the need for users to explicitly list every obstacle in an environment.
- →LLMs are integrated directly into motion planning to handle common-sense reasoning.
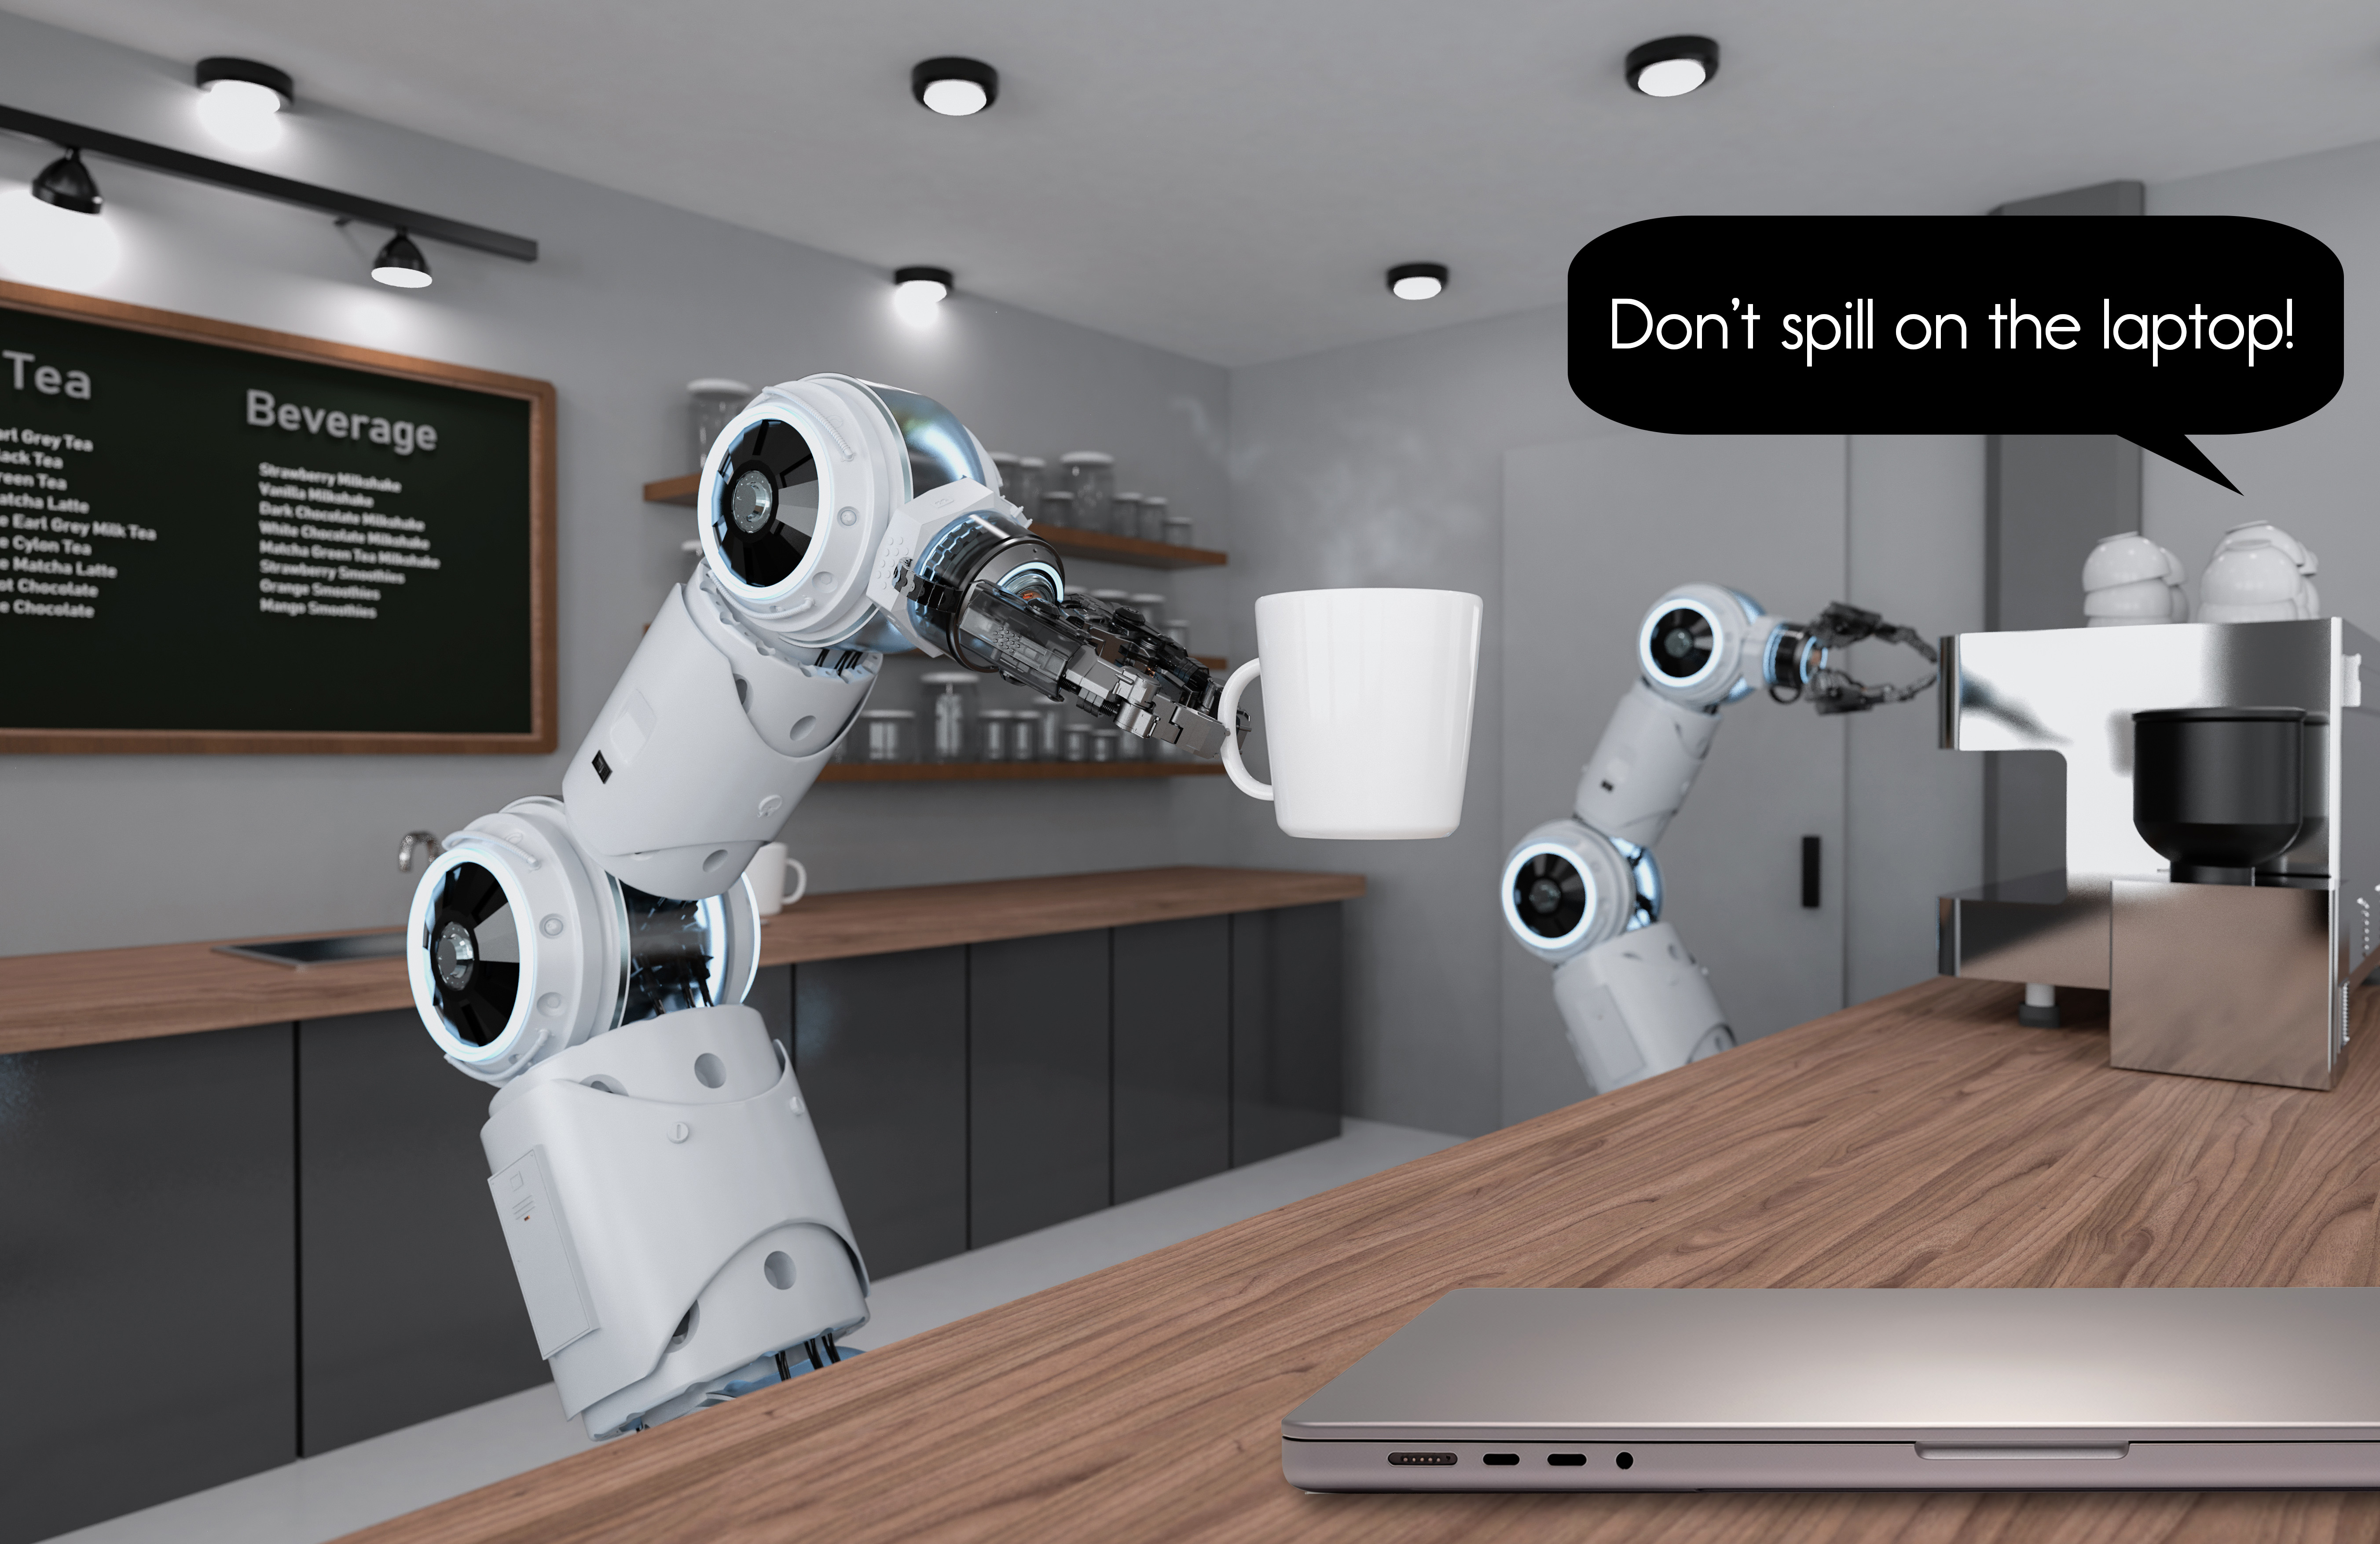
Researchers from MIT and New York University have introduced FLEX, a flexible feature-editing pipeline for robot motion planning presented at the Conference on Robot Learning. The system uses an LLM to interpret natural language commands, allowing robots to infer broader safety constraints from specific user inputs, such as avoiding fragile objects when told not to spill on a laptop. Tested in simulated scenarios involving coffee serving and object transport, FLEX processes these generalizations in approximately five seconds, enabling robots to adapt to unspoken environmental preferences without explicit programming.
Read originalThe story around this
Earlier coverage that leads up to this article, and what followed. Lines connect each piece to the closest one after it, converging here.
More from MIT News AI
More in Research
 © Hugging Face Blog
Researchresearch
Pooling-Aware Training for Multi-Vector Embeddings
Multi-vector models like ColBERT are powerful but storage-heavy, often requiring hundreds of vectors per document. This technique teaches the encoder to preserve retrieval quality even when token vectors are aggressively merged via hierarchical clustering. By training on both full and pooled representations simultaneously, the model learns to compress information without losing critical distinctions. The result is a 4x reduction in vector count with only a marginal drop in accuracy, making large-scale semantic search significantly more efficient.
Hugging Face Blog
 © AI Explained